Work
Research
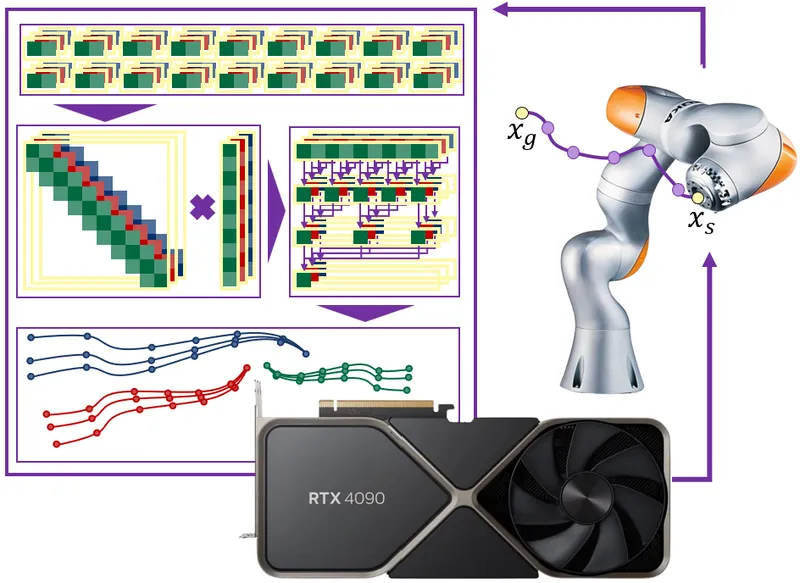
GATO
Batched GPU trajectory optimization for MPC. ICRA 2026.
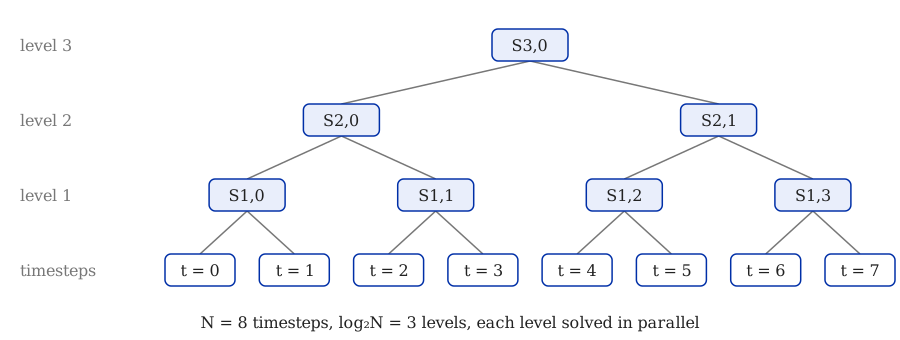
BCHOL
GPU LQR solver using recursive Schur complements.
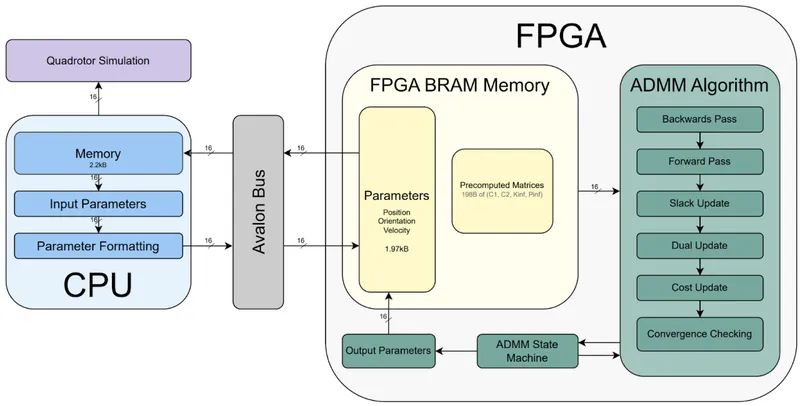
FPGA-MPC
FPGA-accelerated ADMM solver for convex MPC.
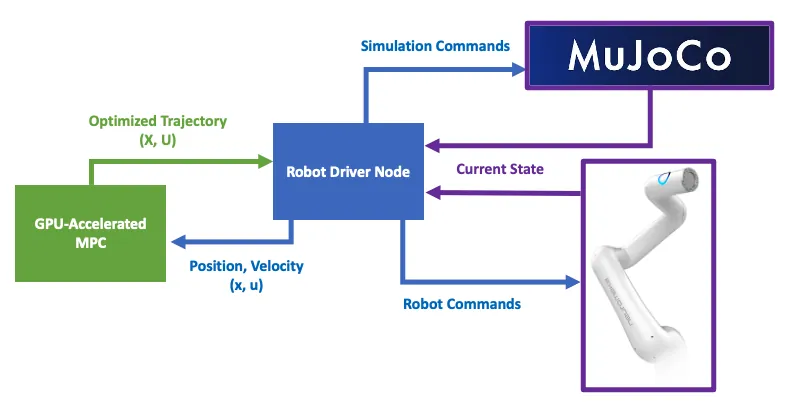
Indy7 SDK
ROS2 package for the Indy7 manipulator.
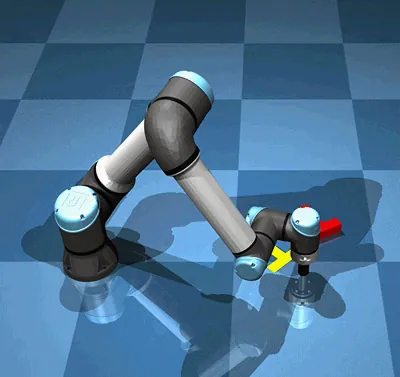
IMM
Inductive Moment Matching on a UR5 Push-T task.
Projects
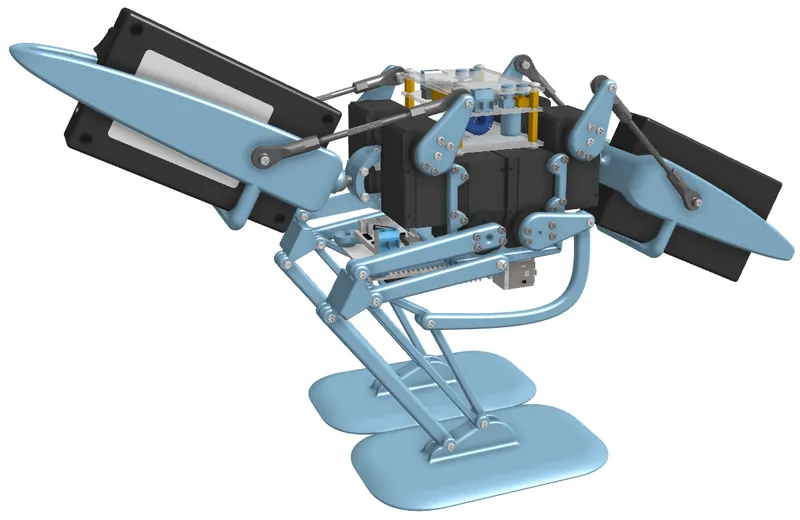
Benji
Biped robot for Columbia's Robotics Studio.
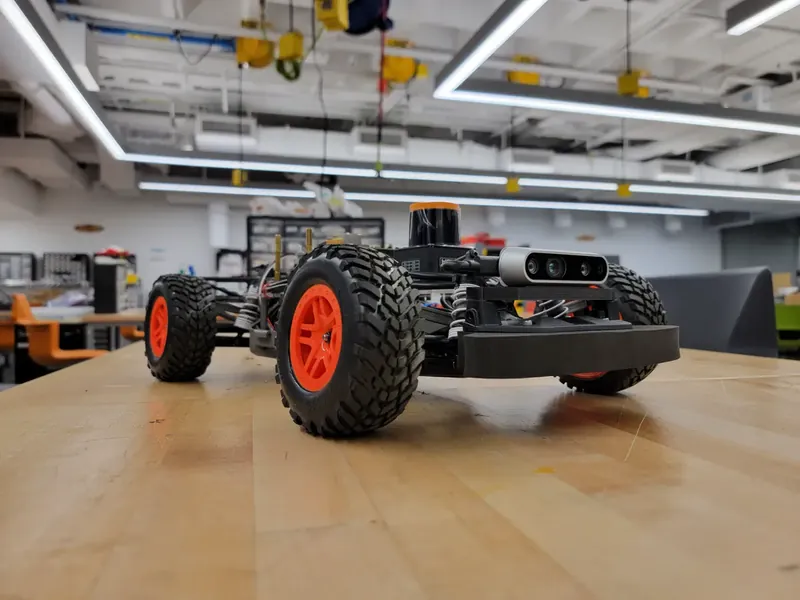
Roboracer
Autonomous F1TENTH-style racer.
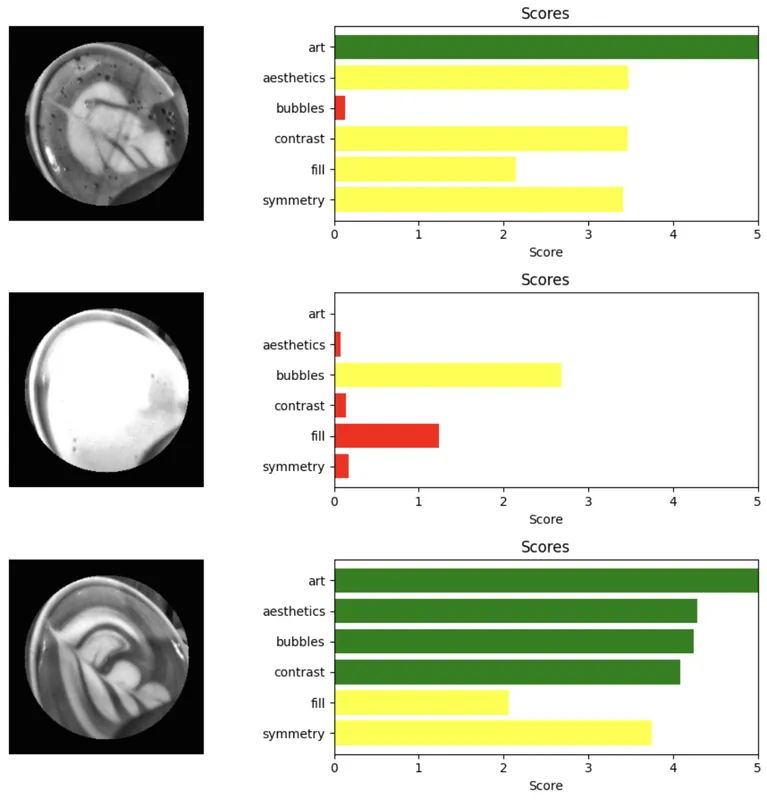
Latte Art CV Pipeline
Scoring latte art for Artly's robotic barista.
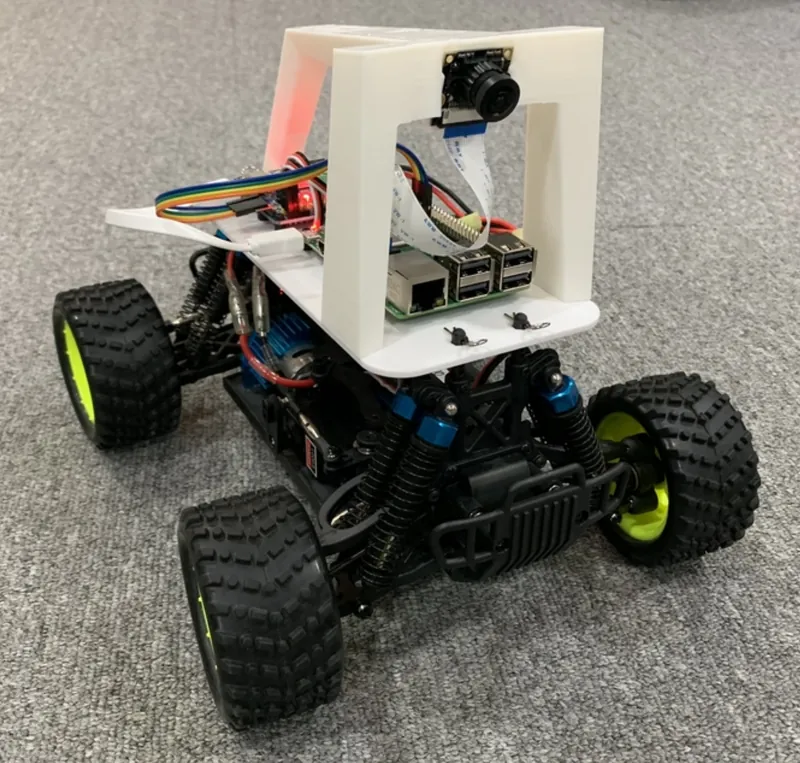
Monocular Obstacle Avoidance
Single-camera collision avoidance at Hanlun AI.
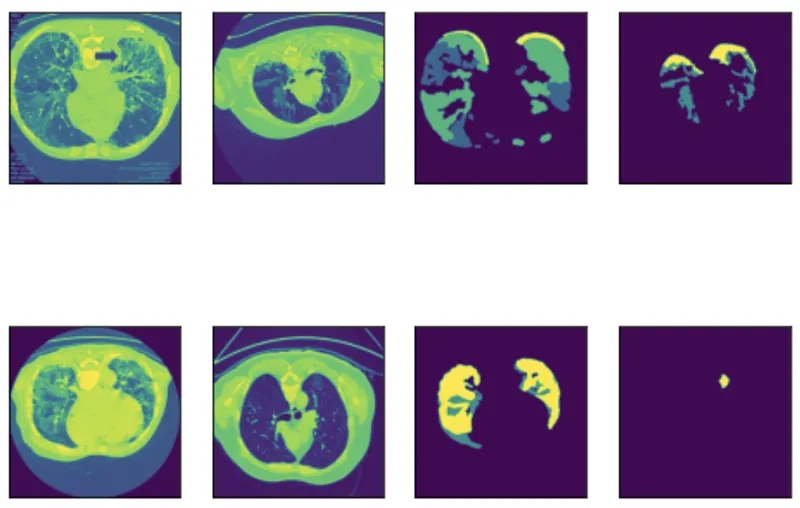
U-Net Covid-19
CT scan segmentation at Hanlun AI.